
September 27 - October 1 | Pittsburgh, US
Booth #408
Get a first look at MANUS Nexus™
Try MANUS Core 3.2 hands-on
Talk with our team about your hand data pipeline.

MANUS Nexus™ lets you reuse the same Top Module across a growing range of MANUS sensor gloves, giving you access to new capabilities without investing in a complete new system for every application.
Choose the glove your application needs: from precision motion capture and haptic teleoperation to scalable data collection and tactile sensing.
Coming with MANUS Core 4.0 in Q1 2027
Move between specialized MANUS sensor gloves using the same Top Module, from high-fidelity motion capture to tactile data.
Add new glove capabilities as your needs evolve, while continuing to build on the hardware you already use.
The same EMF tracking technology and 25-DoF hand model power every Nexus-enabled glove, giving you a consistent motion-data foundation across applications.
One Top Module. Specialized capabilities for different Physical AI workflows.
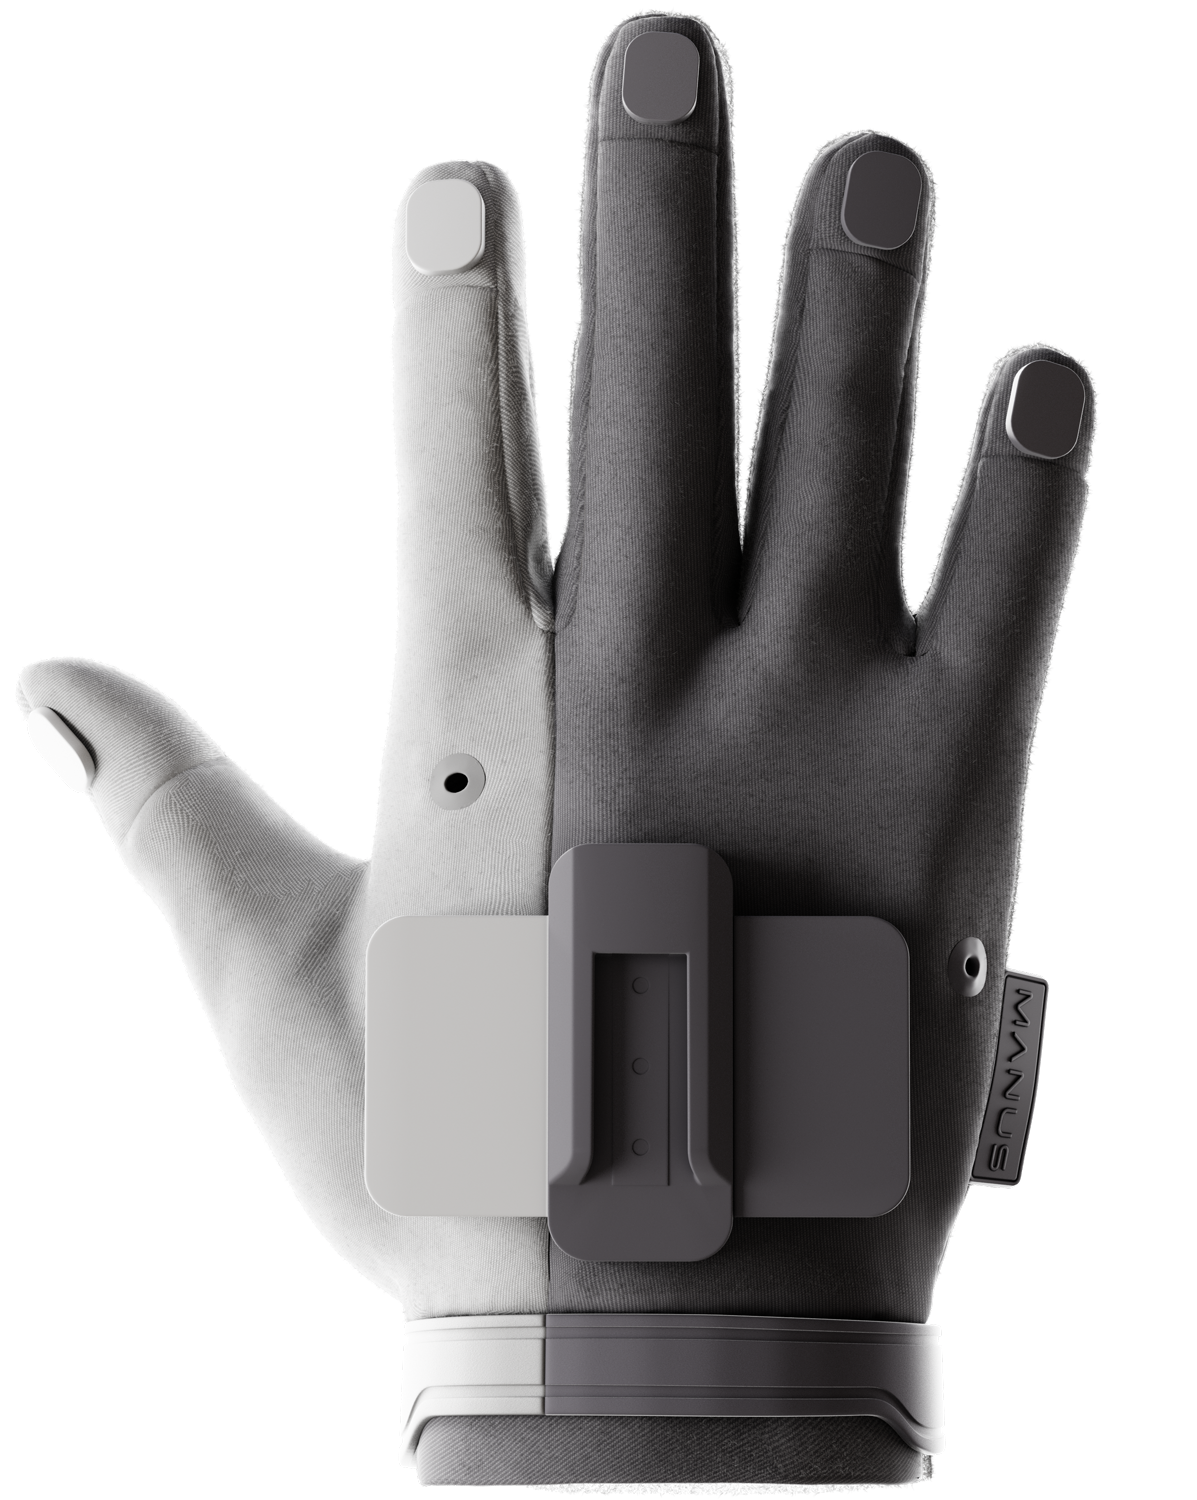

Precision Motion Capture


Haptic Teleoperation
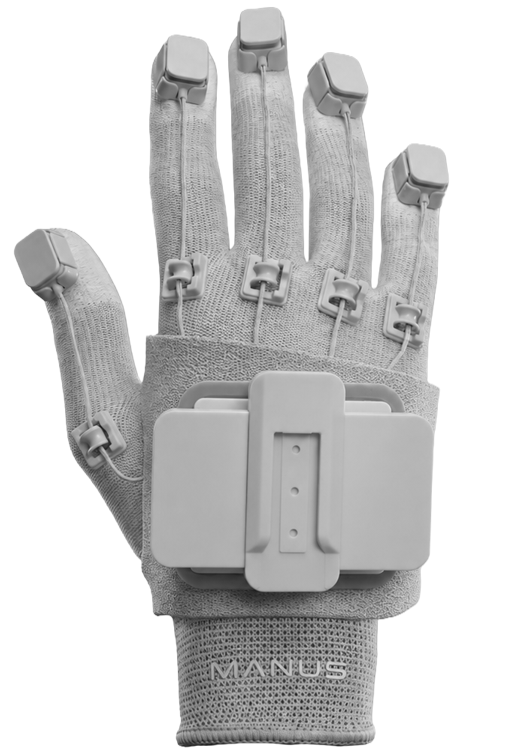

Scalable Data Collection
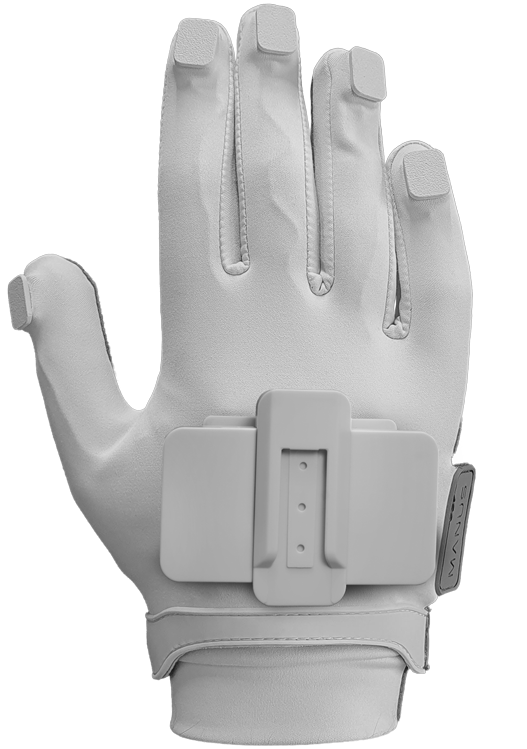

Tactile Data Capture
Deploy MANUS on ARM-based robotics platforms with native support for the Linux SDK and ROS 2 package.
Enhanced calibration better adapts the hand solver to individual hand sizes and proportions, delivering even greater pinch accuracy and consistency across users.
Integrate MANUS hand data directly into Python-based robotics, AI training and development workflows.
Get a first look at MANUS Nexus™, explore MANUS Core 3.2, and talk with our team about your Physical AI data workflows.
Choose an available timeslot during IROS and meet us at Booth #408.