
Introducing MANUS Core 3.2
Expanded ARM64 support, improved pinch calibration, a new Python SDK, and NVIDIA Isaac Teleop haptics.
What’s new in MANUS Core 3.2
MANUS Core 3.2 brings official Linux ARM64 support to the MANUS Core SDK.
ARM64 is widely used across embedded robotics and edge computing platforms, allowing developers to run MANUS closer to their robotic systems without relying on a separate x64 computer.
Core 3.2 has been validated on platforms including NVIDIA Jetson Orin Nano, Raspberry Pi 4, and NVIDIA DGX Spark, with support for Ubuntu 20.04, 22.04, and 24.04.
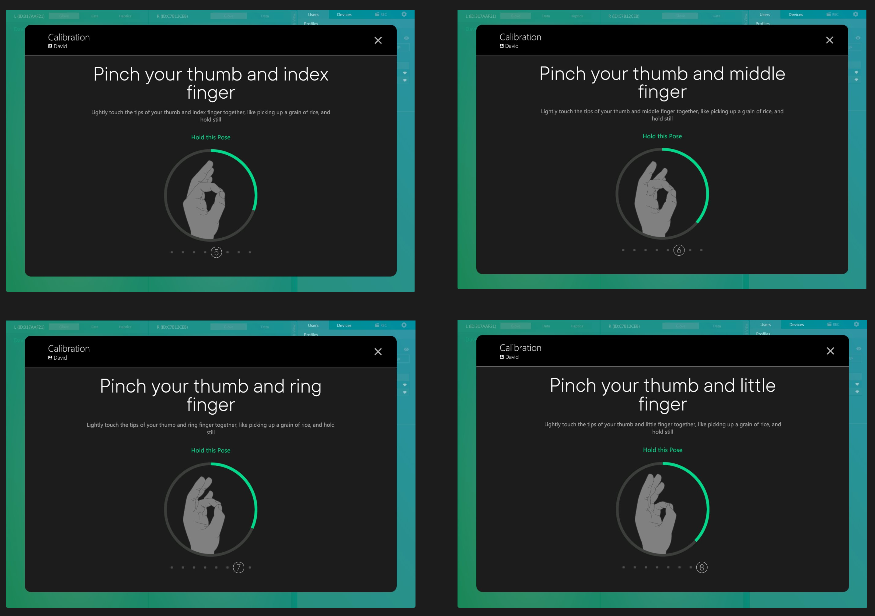
MANUS Core 3.2 introduces an improved thumb-to-finger calibration process that better adapts the hand solver to different hand sizes and proportions.
The result is more precise and consistent pinch tracking across users, with particularly noticeable improvements for smaller hand sizes.
MANUS Core 3.2 introduces a native Python SDK, making it easier to bring high-fidelity MANUS glove data directly into robotics, AI, and machine learning workflows.
Developers can now access MANUS data from Python without building an intermediate C++ integration, making MANUS easier to incorporate into existing research, data collection, and robot learning pipelines.
The Python SDK supports Windows x64 and Linux on both x64 and ARM64.
NVIDIA Isaac Teleop now supports haptic feedback with MANUS Metagloves Pro Haptic.
Simulated events can be mapped to vibrotactile feedback on the gloves, giving operators physical feedback during teleoperation and helping create a more intuitive interaction between the operator and simulated environment.
Haptic feedback can be configured directly within NVIDIA Isaac Teleop environments. Read NVIDIA’s documentation for further information.
Core 3.2 also includes several improvements designed to simplify integration and deployment of the MANUS Core SDK.
The C++ SDK examples have been rebuilt with a clearer, more modular structure, while Linux installation and SDK configuration have been simplified.
For the complete list of technical changes, see the MANUS Core 3.2 release notes.
MANUS Core 3.2 introduces a simplified licensing model with two editions: MANUS Core for Robotics and MANUS Core for Motion Capture.
Both editions are available with subscription-based or perpetual licenses, giving teams more flexibility in how they access MANUS Core.
Customers purchasing a MANUS Core license from Q4 2026 onward will receive one year of software updates.