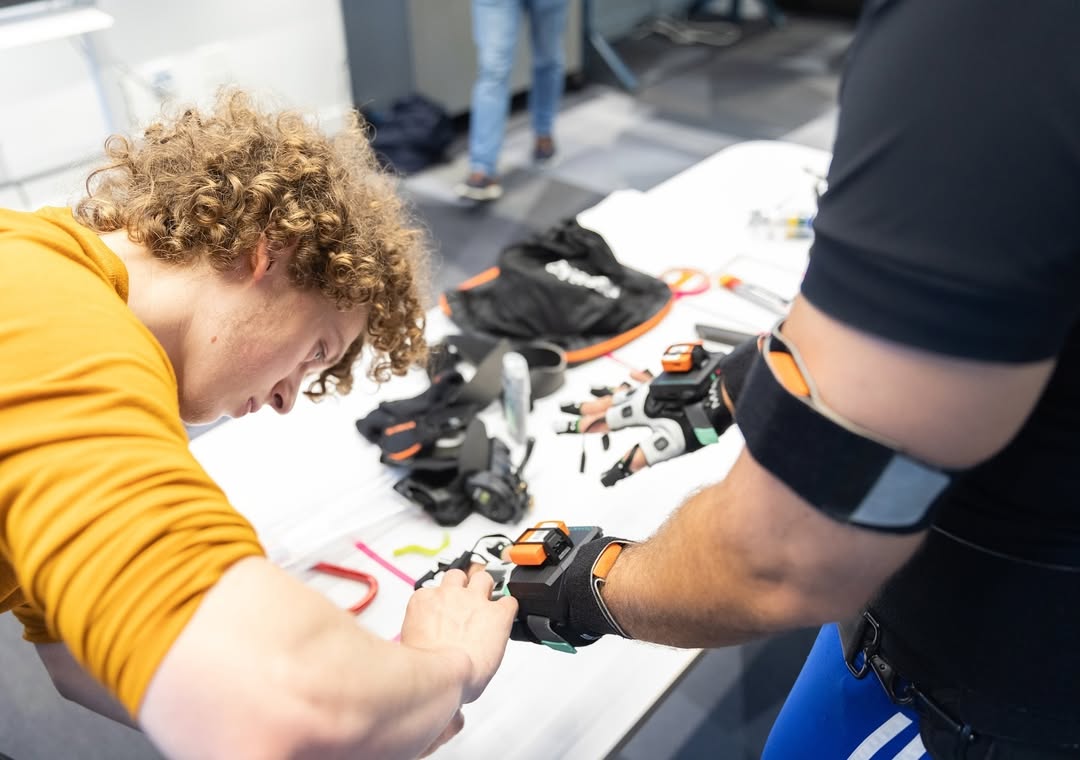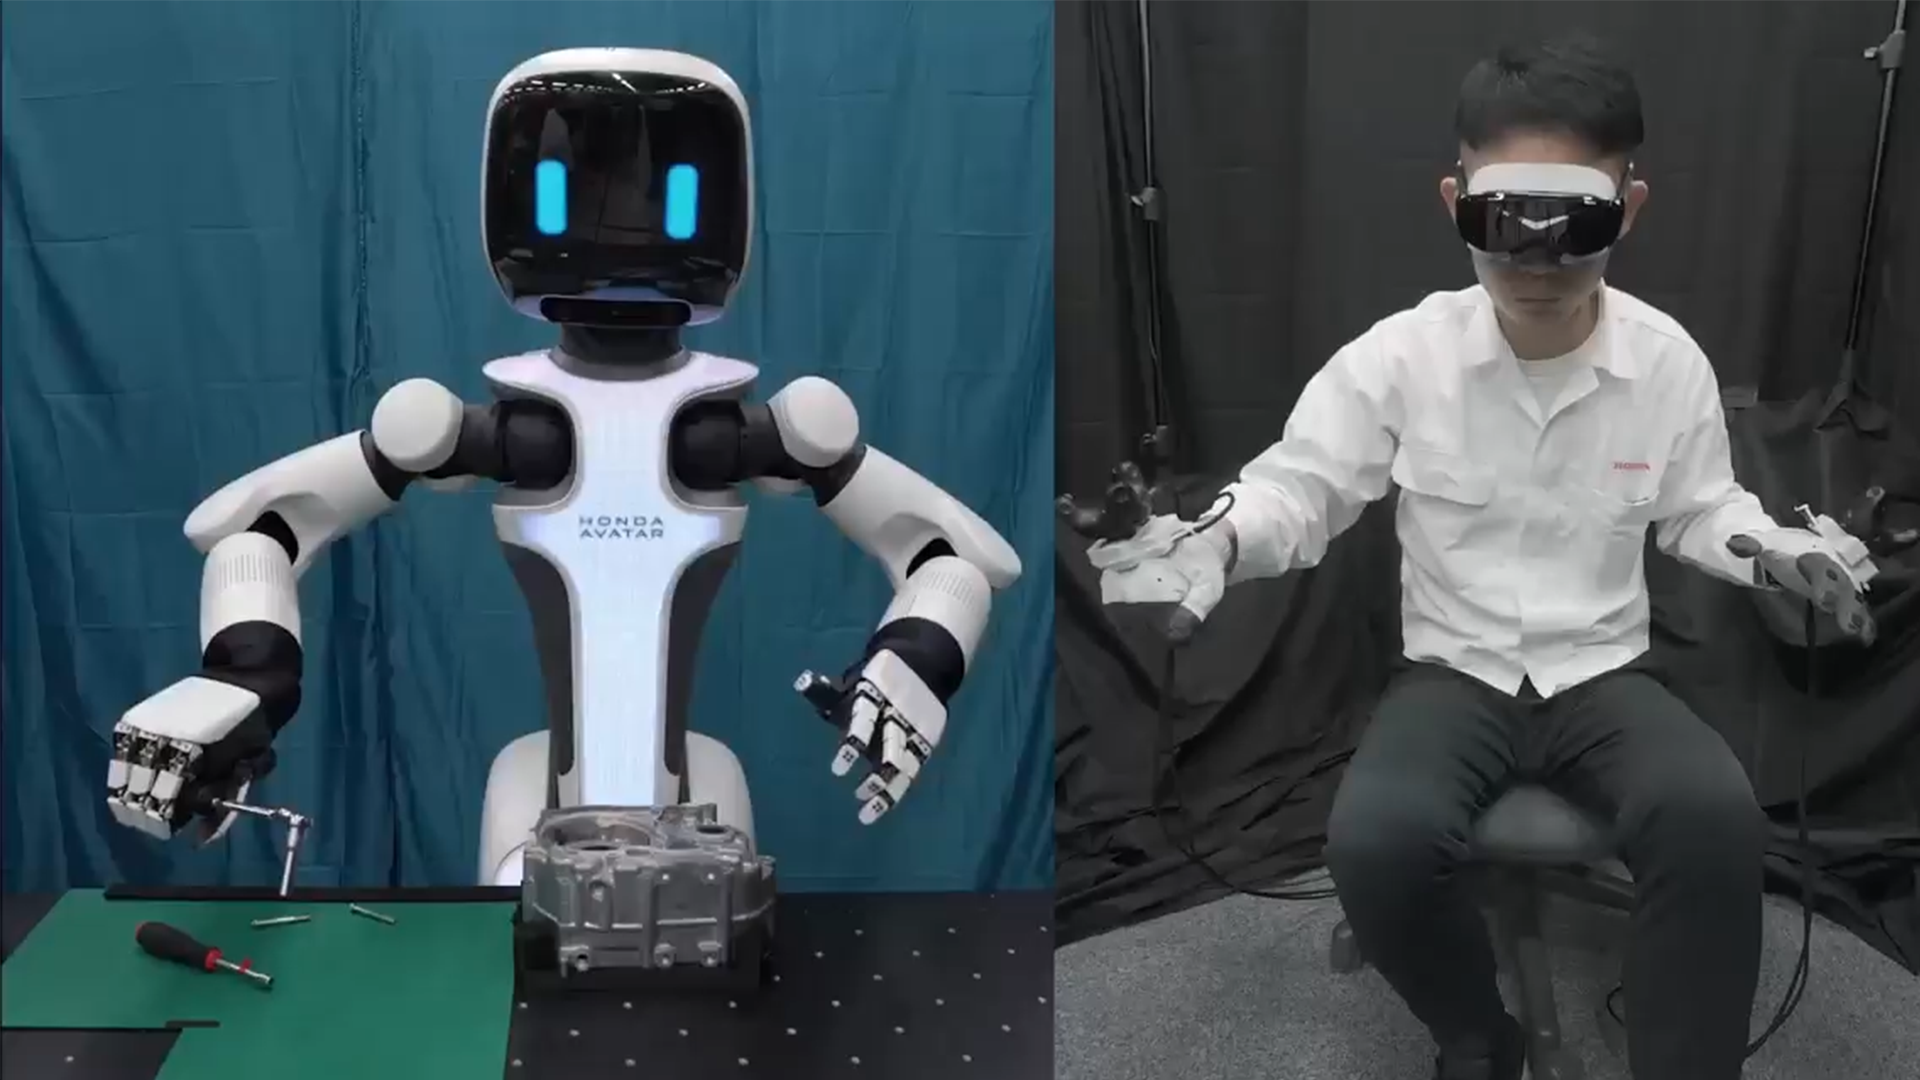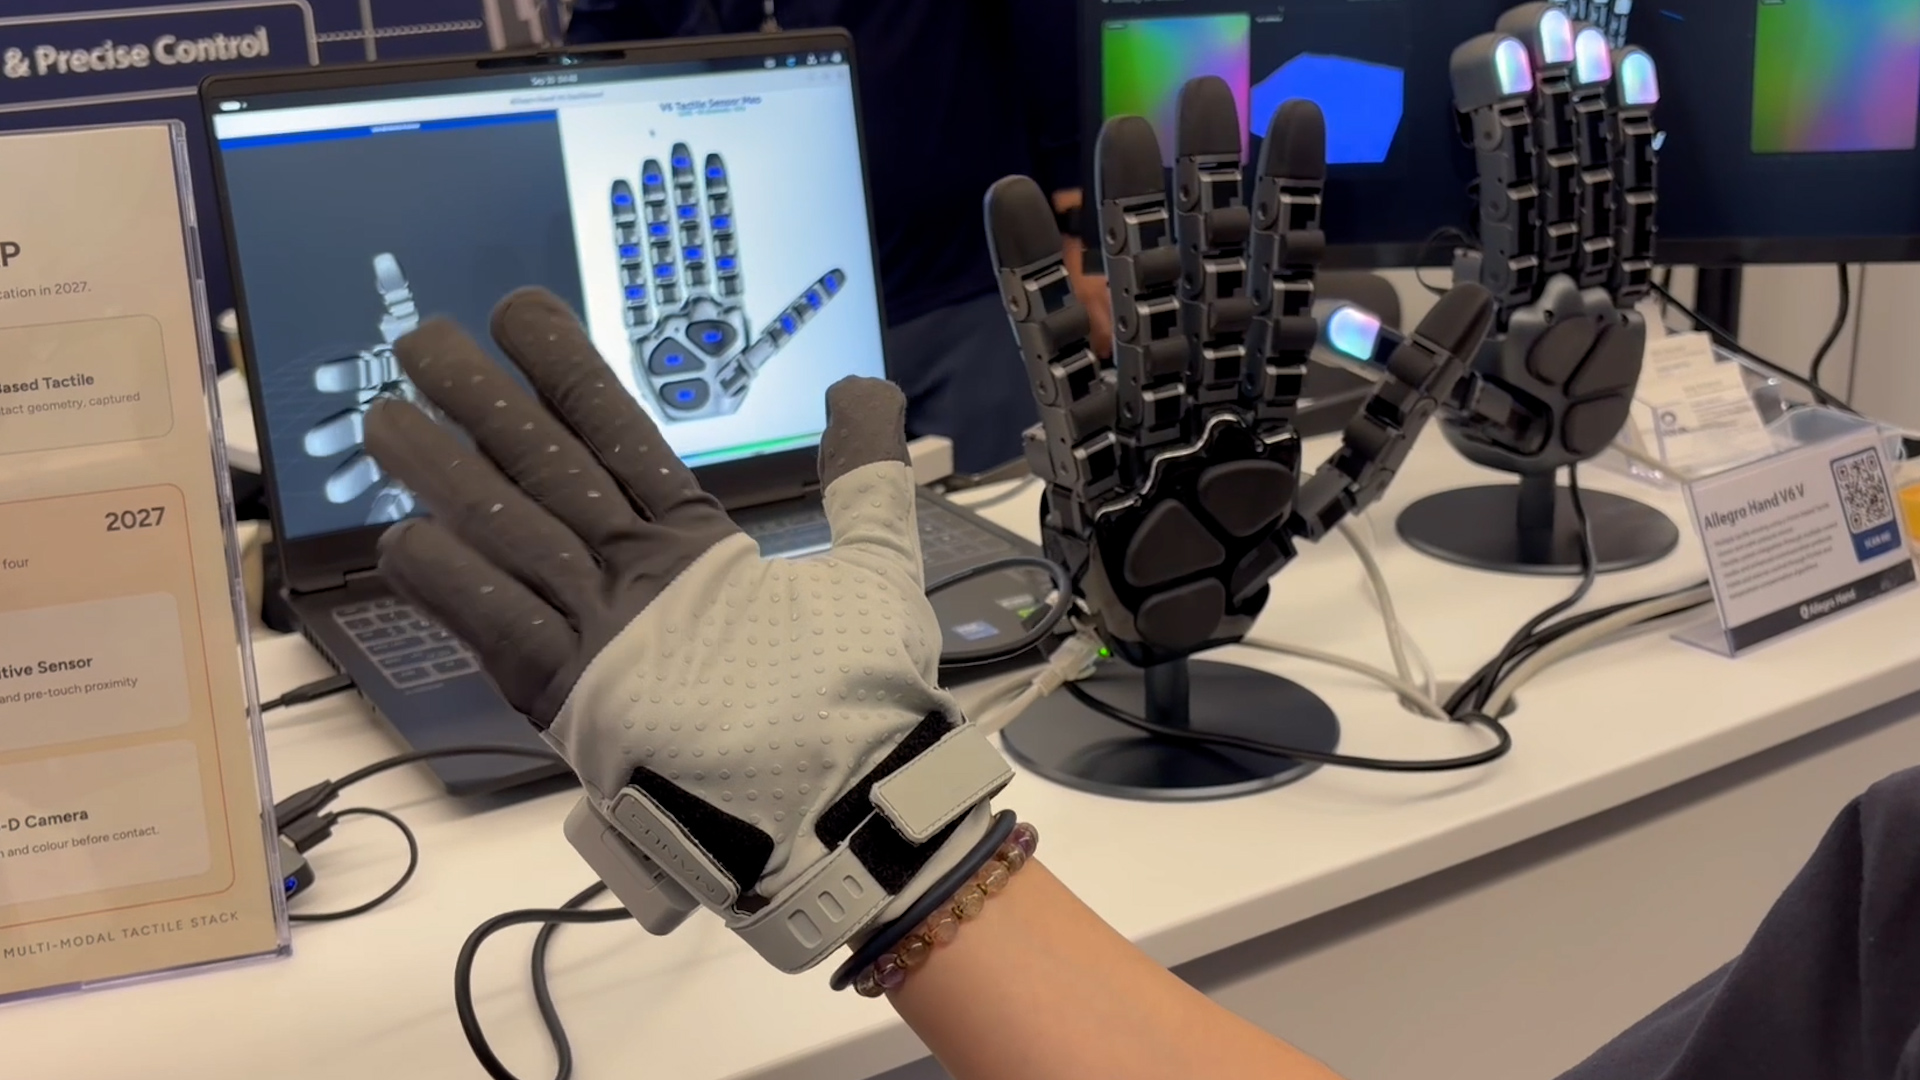


At the official opening of the TUM RoboGym powered by NEURA, MANUS gloves were featured in a robotics demonstration highlighting human input and robotic manipulation. The setting showed how wearable hand tracking can contribute to environments where human demonstrations become usable data for Physical AI.
Opened on 22 October 2026 at the LabCampus near Munich Airport, the 2,300-square-meter TUM RoboGym brings together robotics research, industrial knowledge, and real-world robot training. Its approach combines robot data, human demonstrations, teleoperation, andsimulation. Companies can contribute real workflows while researchers study how robots learn practical tasks and perform them more reliably.

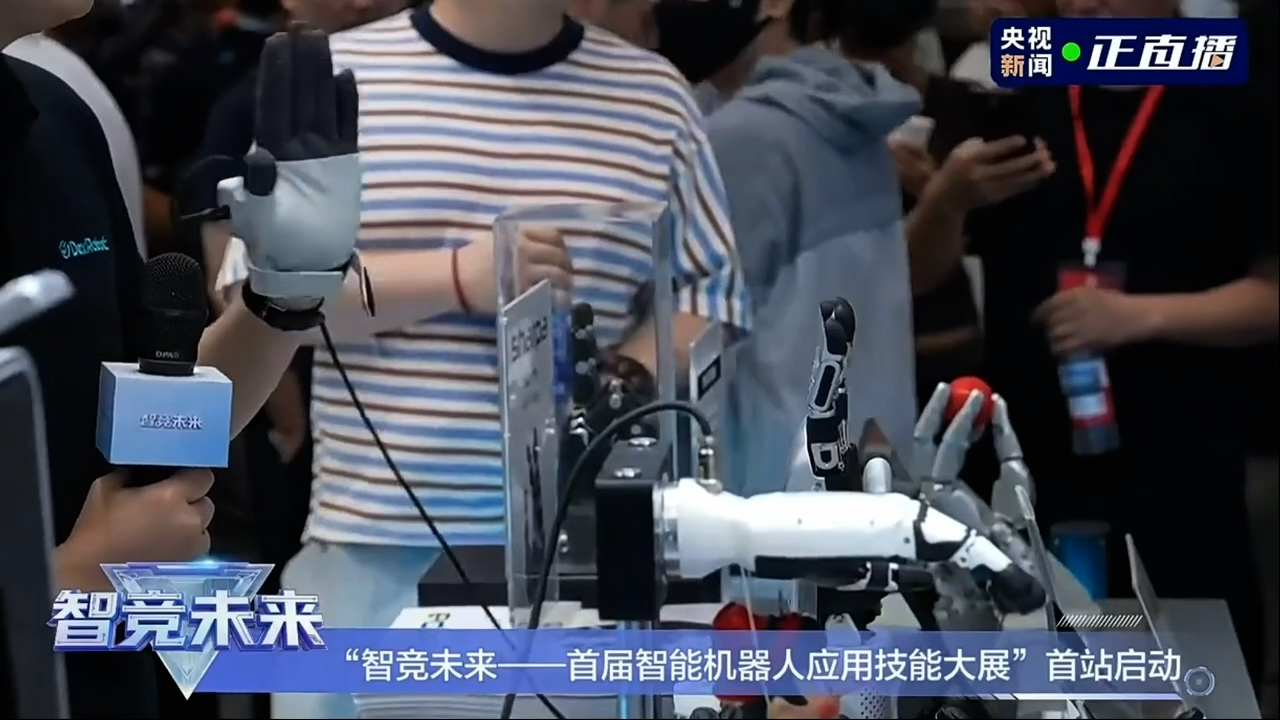
During the launch event, an operator wearing MANUS Metagloves Pro teleoperated the NEURA Robotics’ 4NE1 Gen 4 humanoid robot. The gloves captured the operator’s natural hand and finger movements and supplied them as input for robotic action, placing high-fidelity hand tracking directly inside a live robot interaction workflow.
Metagloves Pro use EMF tracking to capture a complete 25 DoF anatomical hand model with millimeter-level precision, withoutoptical occlusion or drift. Through MANUS Core and the MANUS SDK, this data can be streamed into teleoperation and robot-training pipelines.
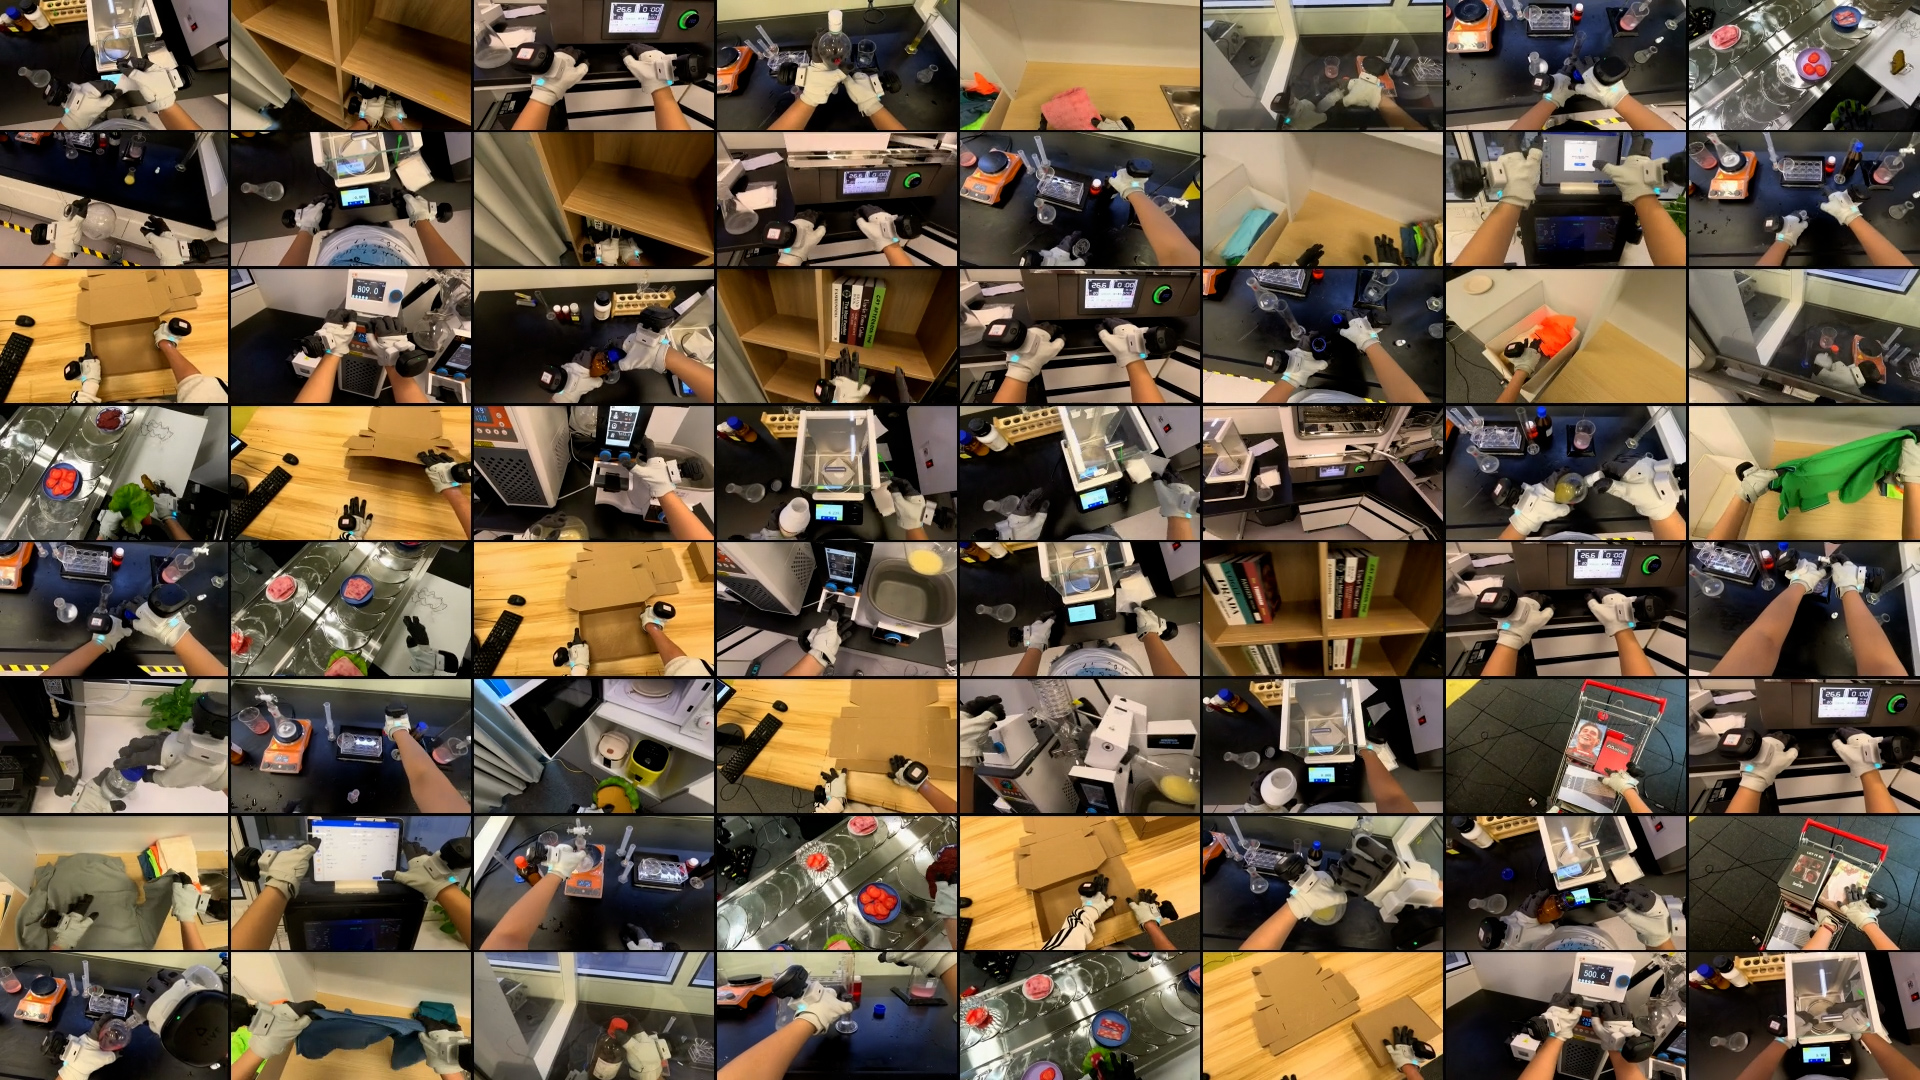
The same pipeline can support more than live control. When hand trajectories are recorded alongside robot state, perception, and task outcomes, teleoperation sessions can become demonstrations for imitation learning and policy fine-tuning. In the RoboGym context, Metagloves Pro therefore connect operator intent, robot execution, and the repeatable data collection needed to develop dexterous manipulation skills.