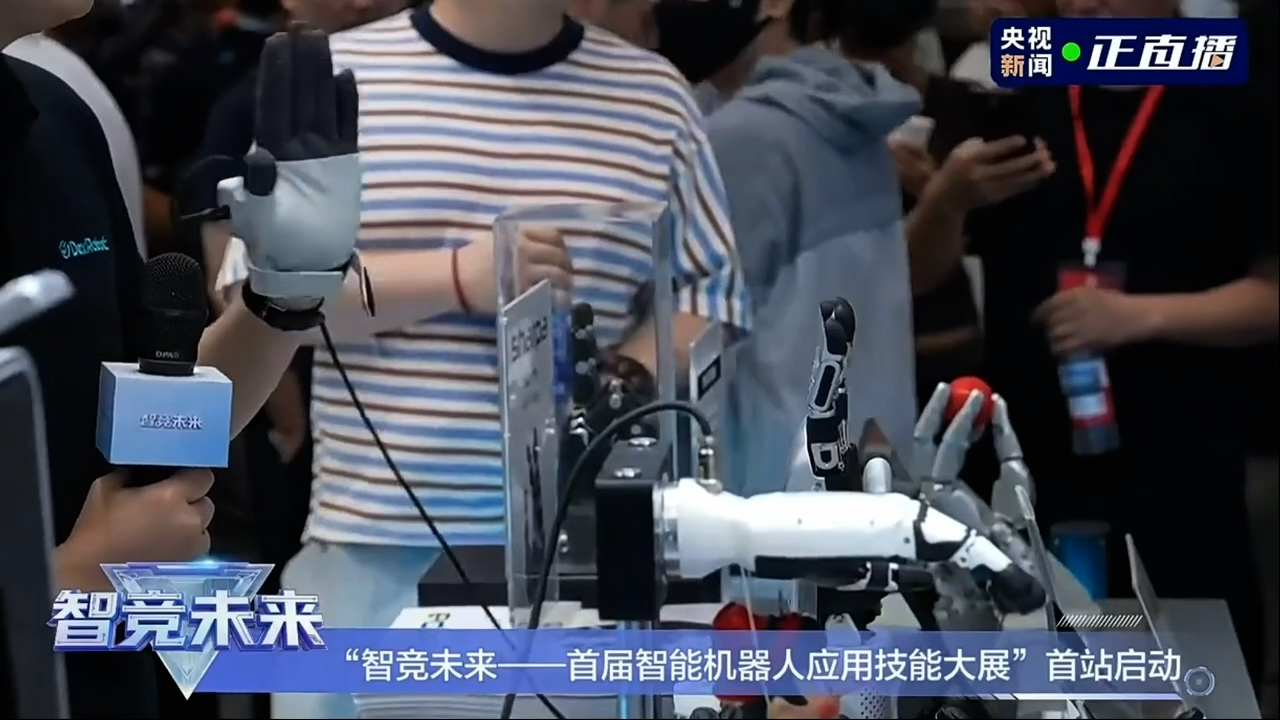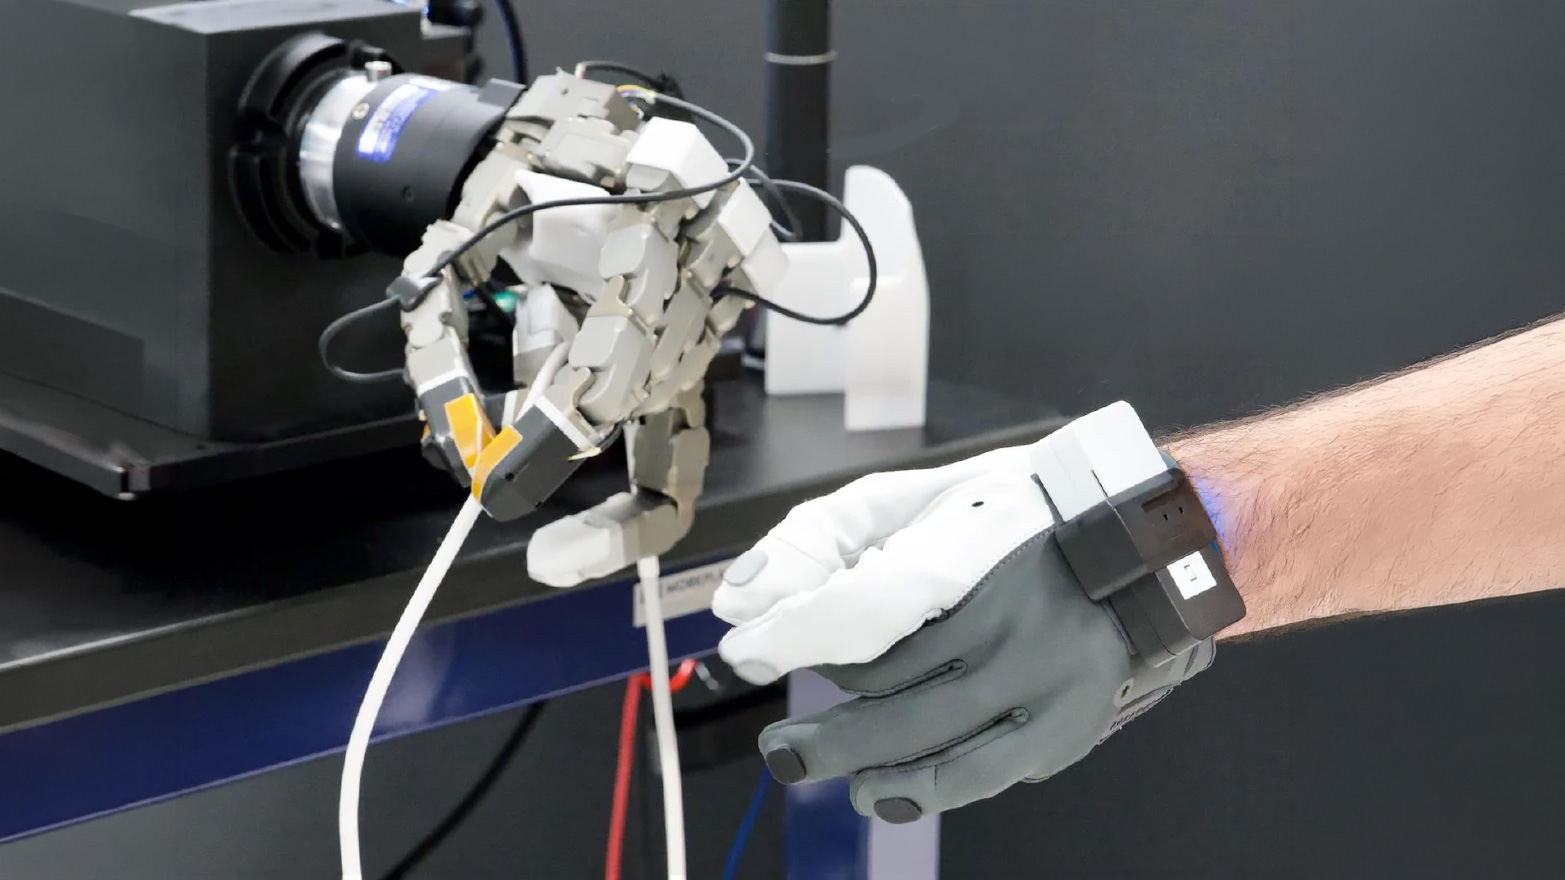

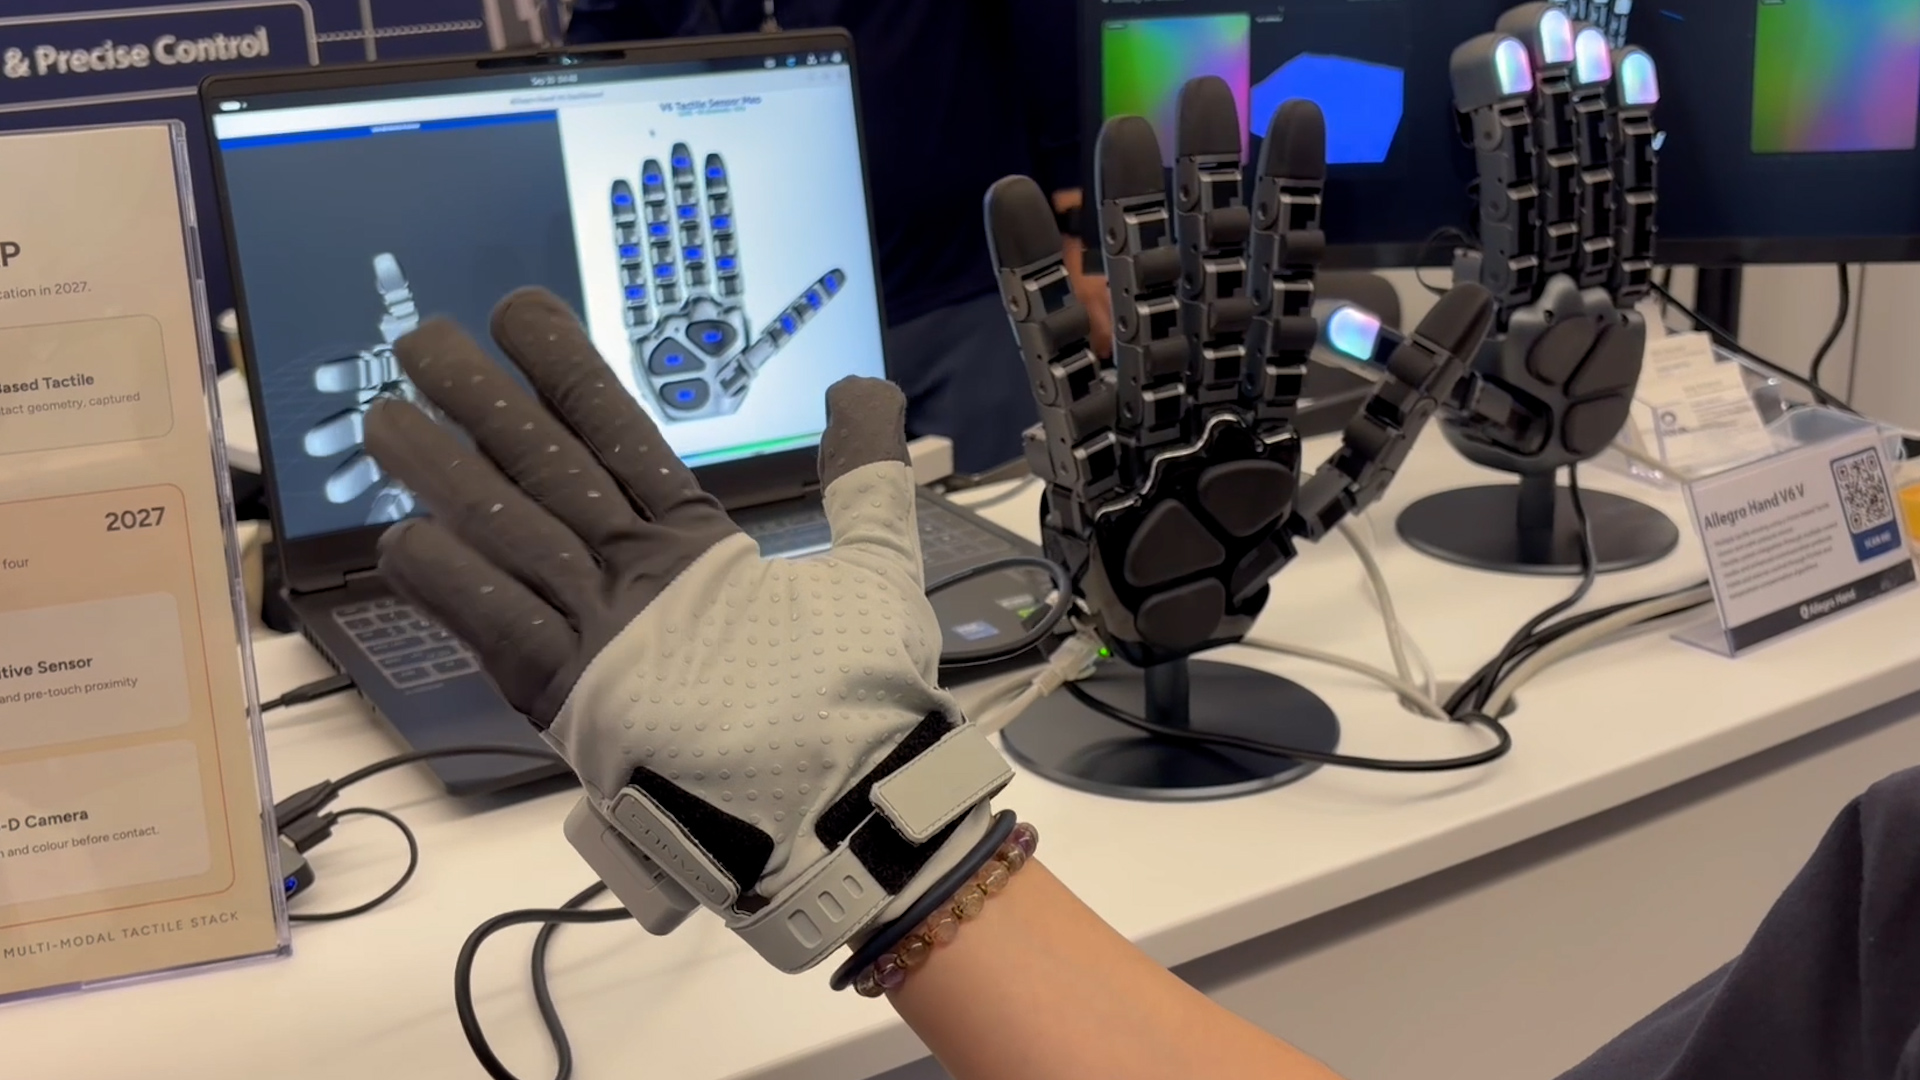
South Korea's Wonik Robotics demonstrated its Allegro Hand V6 using MANUS Metagloves Pro Haptic. The five-finger hand has 20 active degrees of freedom, with DC motor actuation and gear reduction.
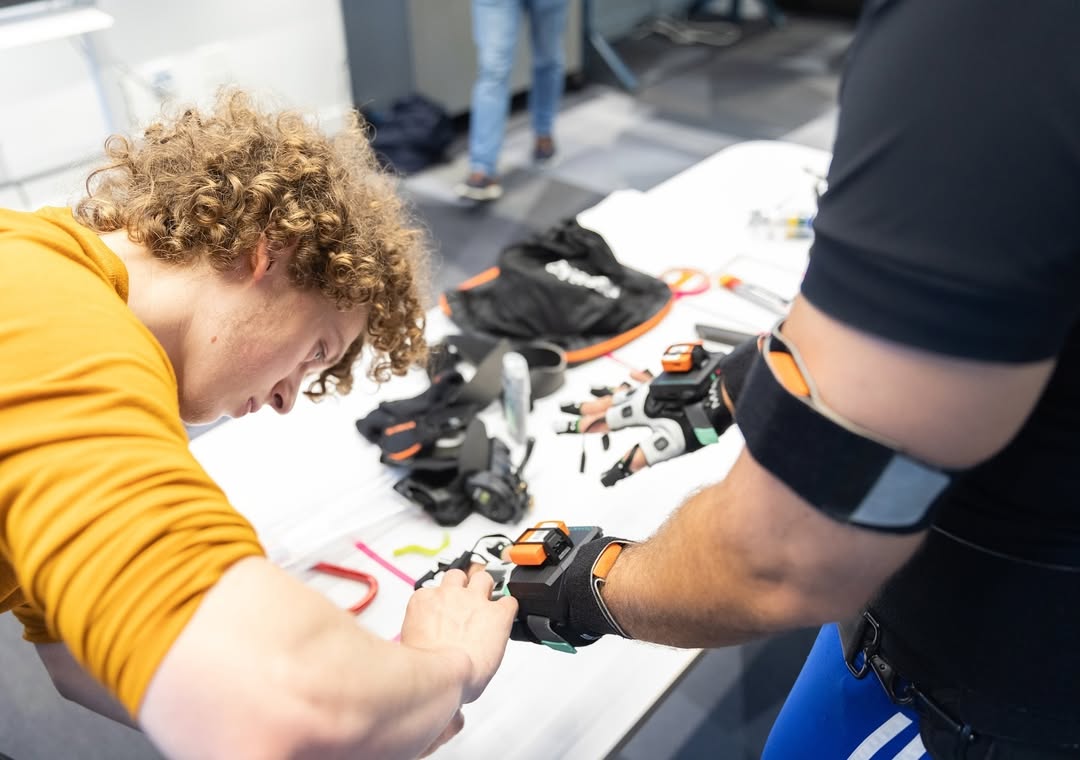
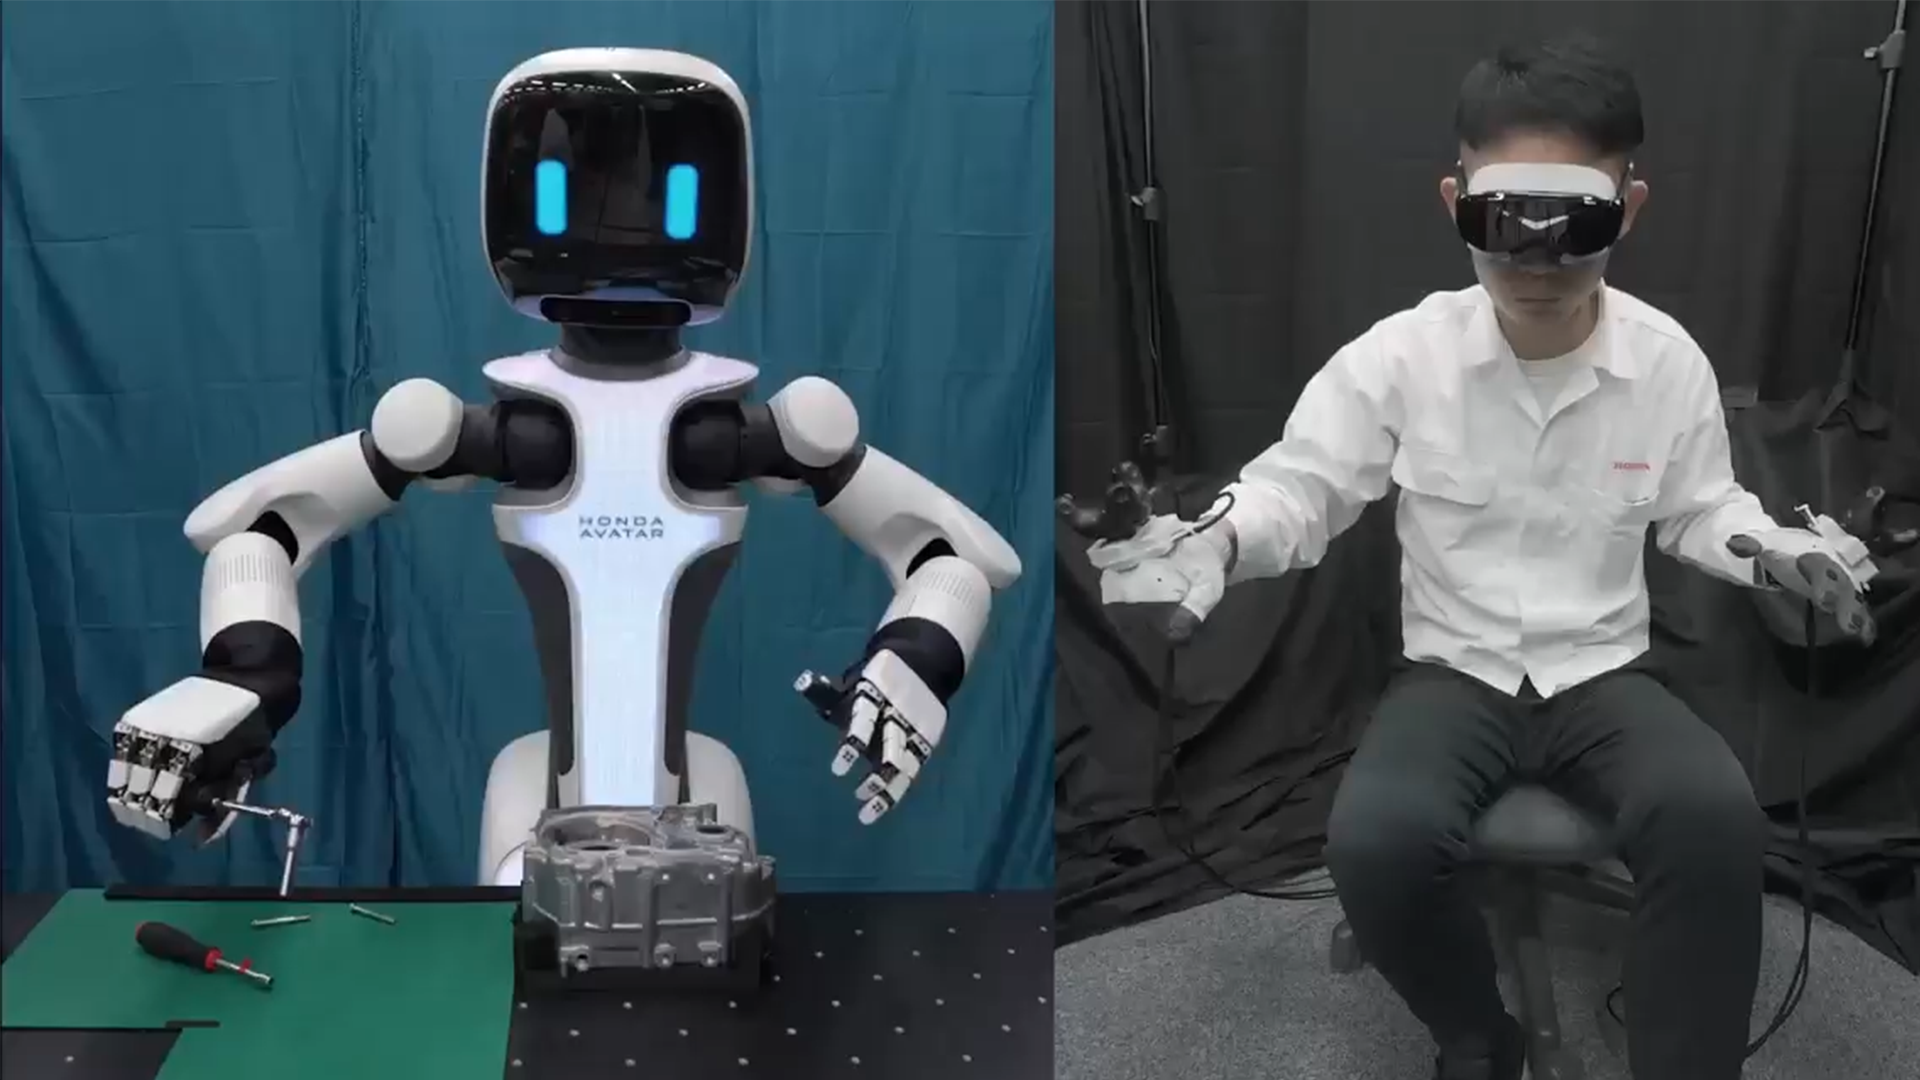
MANUS gloves track fingertip position androtation using electromagnetic field (EMF) sensors. MANUS Core processes these measurements into a 25-DoF anatomical hand model, making joint-angle, fingertip, and skeletal data available to the control pipeline. A retargeting layer adapts human hand motion to the robotic hand’s kinematic structure, providing continuous control input for teleoperation.
The Allegro Hand V6 lineup incorporates tactile sensing to detect object contact during manipulation. With MANUS Metagloves Pro Haptic, robot contact signals can be mapped to vibrotactile feedback on the operator’s corresponding fingers. In a workflow configured for this feedback, the operator receives contact cues alongside visual information, adding a tactile feedback channel to hand motion control.